

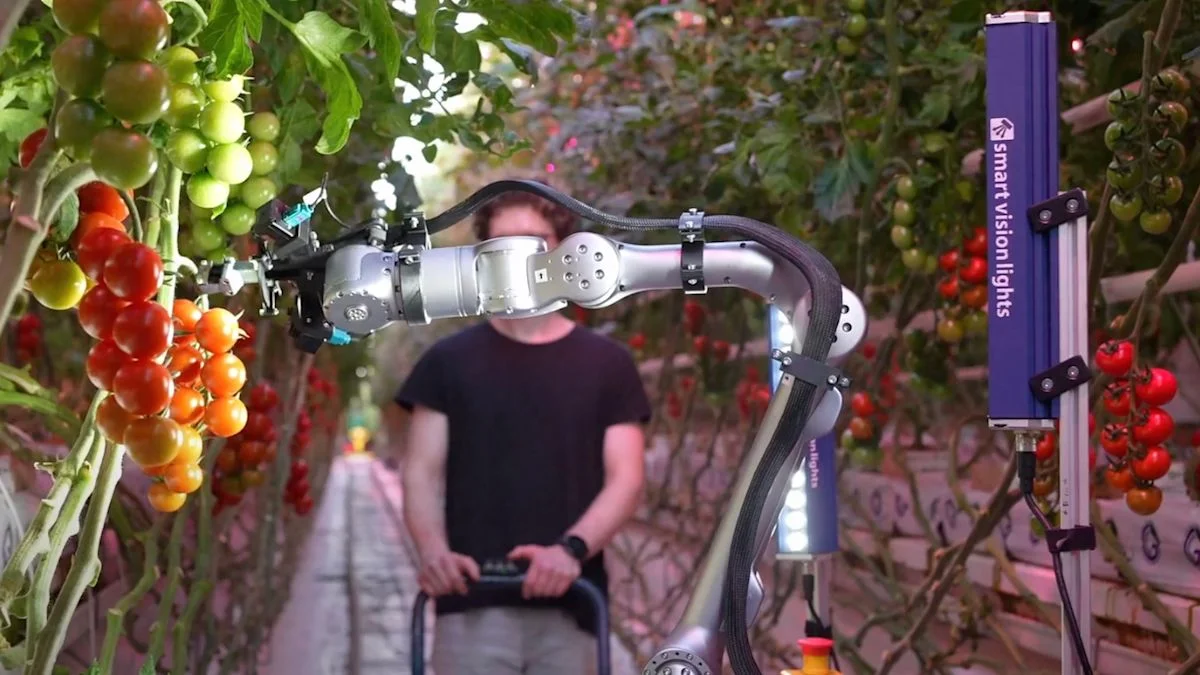
Polybot’s autonomous truss-tomato harvester progressed from its first independent pick in May 2025 to harvesting full greenhouse rows by December, the article reports. The Tübingen startup trains it on human demonstrations rather than hand-coding each step.
Designed for truss tomatoes, the robot must handle fruit carefully among naturally variable plants. A full pilot was planned for summer 2026, with deliveries to growers possible in early 2027 if it succeeds; the September 2026 article does not say whether the pilot took place.
